ROBOT LEARNING · DEXTEROUS MANIPULATION · MULTI-AGENT TEAMING
Harish
Ravichandar
Assistant Professor at Georgia Tech
Director, STAR Lab
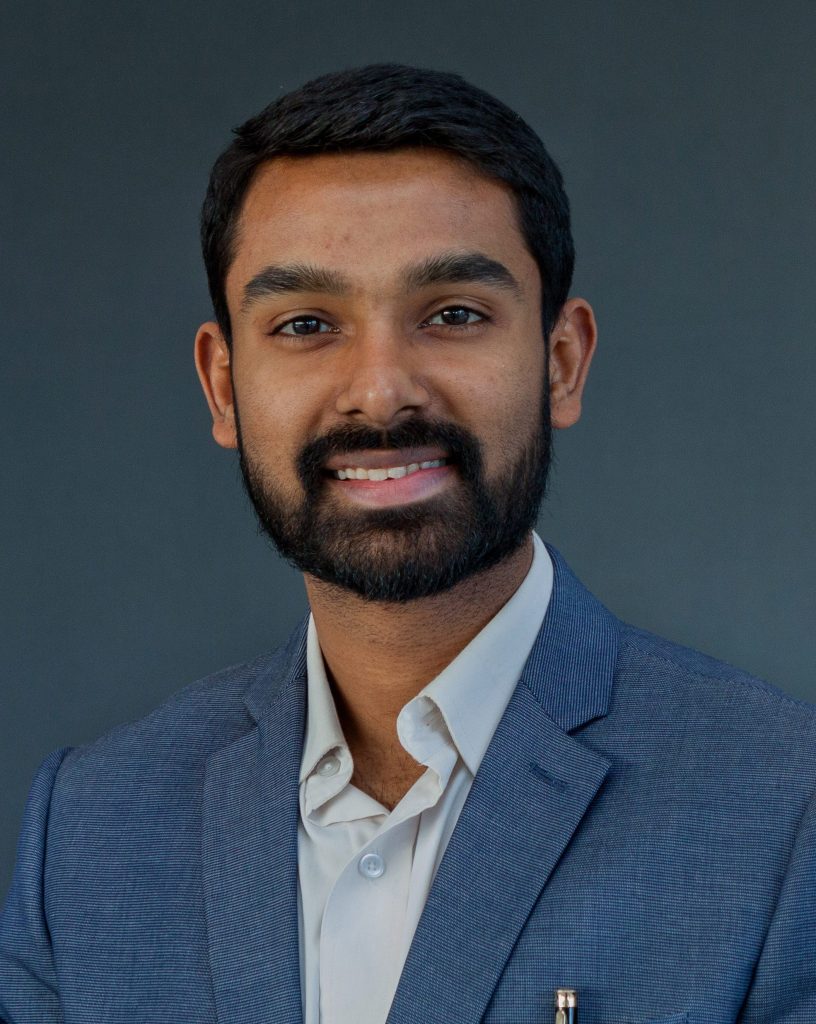
I develop structured approaches to embodied intelligence that combine ideas from robotics, control, and machine learning. My group studies how principled inductive biases can make robots more frugal, self-sufficient, and translucent, with a particular focus on dexterous manipulation and heterogeneous multi-robot coordination.
RESEARCH
A structured approach to robotic intelligence
Classical robotics as scaffolding for modern robot learning.
My research asks how the inherent structures of the physical and resource-constrained world—geometry, dynamics, embodiment, capabilities, and constraints—can serve as generalizable priors for learning and decision-making. The goal is robot intelligence that uses data and computation efficiently, improves with less expert intervention, and behaves in ways that are easier to anticipate and understand.
Structured Skill Learning
Leveraging geometry, dynamics, and interaction to make complex robot skills—especially dexterous manipulation—easier to learn, transfer, refine, and adapt.
Structured Coordination
Developing capability-centric models and algorithms for heterogeneous robot teams that must allocate tasks, plan, schedule, communicate, and act together.
Structured Adaptation
Enabling robots to respond to uncertainty, failures, and changing environments by updating what must change while preserving useful models, decisions, and experience.
ABOUT
I am an Assistant Professor in the School of Interactive Computing at the Georgia Institute of Technology, a core faculty member of the Institute for Robotics and Intelligent Machines (IRIM), and a faculty member of the Machine Learning Center (ML@GT). I direct the Structured Techniques for Algorithmic Robotics (STAR) Lab.
My work has been recognized by the NSF CAREER Award, several best paper and oral spotlight honors, the UTC Institute for Advanced Systems Engineering Doctoral Fellowship, and the Outstanding Post-Doctoral Research Award at Georgia Tech.
Before joining the faculty in 2021, I was a Postdoctoral Fellow and Research Scientist at Georgia Tech. I received my Ph.D. from the University of Connecticut, my M.S. from the University of Florida, and my B.E. from Anna University
I teach Introduction to Robotics (CS 3630), Advanced Robot Manipulation (ARM, CS 4803), and Multi-Agent Coordination (CS 7631) at Georgia Tech.
 Harish Ravichandar
